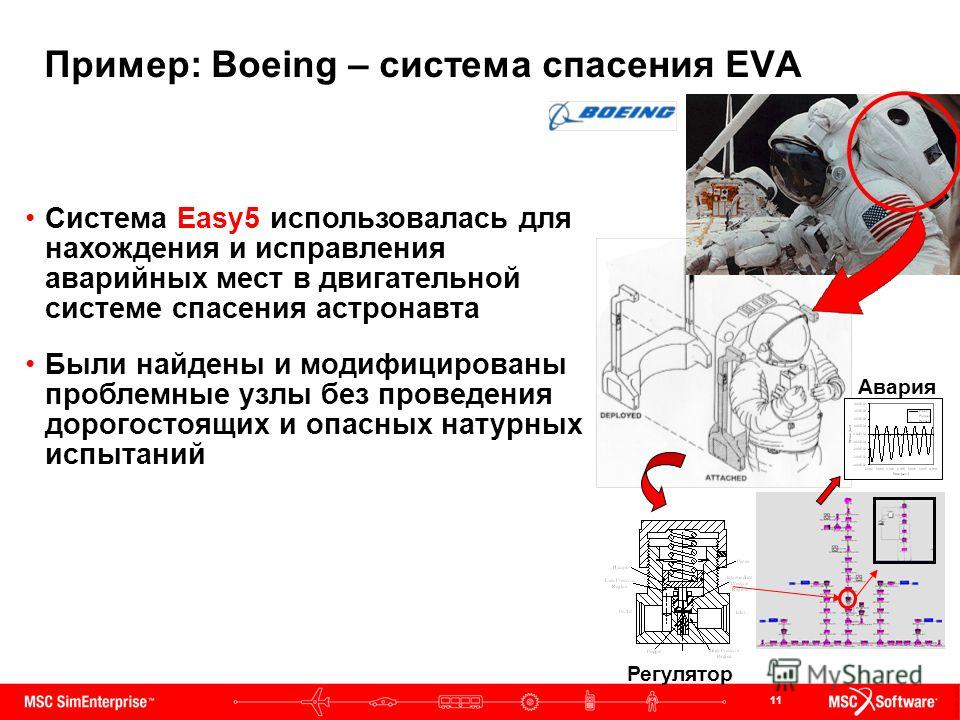
Msc Easy5
Posted in:admin
Engineering aircraft, vehicles, agricultural equipment, and other complex systems requires a systemsengineering approach in which not only the components and. Users We are transitioning to a newandimproved community collaboration platform. Vice Versa Pro Full on this page. This site is now readonly for the purposes of search and browse. A Distrim Sistemas, integrada no Grupo Vangest, lder no fornecimento de solues CADCAMCAEPLM CATIA, ENOVIA, SmarTeam, EXALEAD, MSC Software, Spinfire. Msc Easy5 Training KI8008069 Errors in creation of EASY5 2010 ez5vars. KI8008071 EASY5 2010 cant find Intel Fortran compiler KI8008132 When trying to launch EASY5. Sign In Password Help Start here. Get what you want from MSC more efficiently and effectively, either reactively through browsing and searching, or proactively. CADCAM MSC Software License File,For EVALUATION only MSC Adams 2017. Msc Easy5' title='Msc Easy5' />
 Fundamentals of Dynamic Analysis MSC Nastran Simulating Reality, Delivering Certainty. Overview. In static structural analysis, it is possible to describe the operation of MSC Nastran without a detailed discussion of the fundamental equations. Due to the several types of dynamic analyses and the different mathematical form of each, some knowledge of both the physics of dynamics and the manner in which the physics is represented is important to using MSC Nastran effectively and efficiently for dynamic analysis. You should become familiar with the notation and terminology covered in this chapter. Msc Easy5 V2013landThis knowledge will be valuable to understand the meaning of the symbols and the reasons for the procedures employed in later chapters. Vector Nti Express Mac Cracks more. References and Bibliography, 7. Dynamic Analysis Versus Static Analysis. Two basic aspects of dynamic analysis differ from static analysis. First, dynamic loads are applied as a function of time or frequency. Second, this time or frequency varying load application induces time or frequency varying response displacements, velocities, accelerations, forces, and stresses. These time or frequency varying characteristics make dynamic analysis more complicated and more realistic than static analysis. This chapter introduces the equations of motion for a single degree of freedom dynamic system see Equations of Motion, 3, illustrates the dynamic analysis process see Dynamic Analysis Process, 1. Dynamic Analysis Types, 1. Those who are familiar with these topics may want to skip to subsequent chapters. Lindo 6.1 Serial Number there. Msc Easy5' title='Msc Easy5' />Functional Mockup Interface FMI is a tool independent standard to support both model exchange and cosimulation of dynamic models using a combination of xmlfiles. Msc Easy5 Tutorial' title='Msc Easy5 Tutorial' />Equations of Motion. The basic types of motion in a dynamic system are displacement u and the first and second derivatives of displacement with respect to time. These derivatives are velocity and acceleration, respectively, given below 1 1Velocity and Acceleration. Velocity is the rate of change in the displacement with respect to time. Velocity can also be described as the slope of the displacement curve. Similarly, acceleration is the rate of change of the velocity with respect to time, or the slope of the velocity curve. Single Degree of Freedom System. The most simple representation of a dynamic system is a single degree of freedom SDOF system see Figure 1 1. In an SDOF system, the time varying displacement of the structure is defined by one component of motion ut. Velocity ut and acceleration t are derived from the displacement. Dynamic and Static Degrees of Freedom. Mass and damping are associated with the motion of a dynamic system. Degrees of freedom with mass or damping are often called dynamic degrees of freedom degrees of freedom with stiffness are called static degrees of freedom. It is possible and often desirable in models of complex systems to have fewer dynamic degrees of freedom than static degrees of freedom. The four basic components of a dynamic system are mass, energy dissipation damper, resistance spring, and applied load. As the structure moves in response to an applied load, forces are induced that are a function of both the applied load and the motion in the individual components. The equilibrium equation representing the dynamic motion of the system is known as the equation of motion. Equation of Motion. This equation, which defines the equilibrium condition of the system at each point in time, is represented as1 2The equation of motion accounts for the forces acting on the structure at each instant in time. Typically, these forces are separated into internal forces and external forces. Internal forces are found on the left hand side of the equation, and external forces are specified on the right hand side. The resulting equation is a second order linear differential equation representing the motion of the system as a function of displacement and higher order derivatives of the displacement. Inertia Force. An accelerated mass induces a force that is proportional to the mass and the acceleration. This force is called the inertia force mt. Viscous Damping. The energy dissipation mechanism induces a force that is a function of a dissipation constant and the velocity. This force is known as the viscous damping force but. The damping force transforms the kinetic energy into another form of energy, typically heat, which tends to reduce the vibration. Elastic Force. The final induced force in the dynamic system is due to the elastic resistance in the system and is a function of the displacement and stiffness of the system. This force is called the elastic force or occasionally the spring force kut. Applied Load. The applied load pt on the right hand side of Eq. This load is independent of the structure to which it is applied e. Solution of the Equation of Motion. The solution of the equation of motion for quantities such as displacements, velocities, accelerations, andor stressesall as a function of timeis the objective of a dynamic analysis. The primary task for the dynamic analyst is to determine the type of analysis to be performed. The nature of the dynamic analysis in many cases governs the choice of the appropriate mathematical approach. The extent of the information required from a dynamic analysis also dictates the necessary solution approach and steps. Dynamic analysis can be divided into two basic classifications free vibrations and forced vibrations. Free vibration analysis is used to determine the basic dynamic characteristics of the system with the right hand side of Eq. If damping is neglected, the solution is known as undamped free vibration analysis. Free Vibration Analysis. In undamped free vibration analysis, the SDOF equation of motion reduces to1 3Eq. The quantity ut is the solution for the displacement as a function of time t. As shown in Eq. 1 4, the response is cyclic in nature. Circular Natural Frequency. One property of the system is termed the circular natural frequency of the structure n. The subscript n indicates the natural for the SDOF system. In systems having more than one mass degree of freedom and more than one natural frequency, the subscript may indicate a frequency number. For an SDOF system, the circular natural frequency is given by1 5The circular natural frequency is specified in units of radians per unit time. Natural Frequency. The natural frequency fn is defined by1 6The natural frequency is often specified in terms of cycles per unit time, commonly cycles per second cps, which is more commonly known as Hertz Hz. This characteristic indicates the number of sine or cosine response waves that occur in a given time period typically one second. The reciprocal of the natural frequency is termed the period of response Tn given by1 7The period of the response defines the length of time needed to complete one full cycle of response. In the solution of Eq. A and B are the integration constants. These constants are determined by considering the initial conditions in the system. Since the initial displacement of the system ut 0 and the initial velocity of the system ut 0 are known, A and B are evaluated by substituting their values into the solution of the equation for displacement and its first derivative velocity, resulting in1 8These initial value constants are substituted into the solution, resulting in1 9Eq. SDOF system as a function of its initial displacement and velocity.